National Institute of Technology, Tiruchirappalli
B.Tech, Instrumentation & Control Engineering (Minor: Computer Applications)
§ 00 // PROFILE
Observing Through Sensors,Controlling Through Censors,Tames the Chaos.
CONTROL · ROBOTICS · SIMULATION // NIT TRICHY / IIT MADRAS / EPFL
FOR BROTHERHOOD? WHY DON'T YOU TRY USING THE UNAUTHORISED TERMINAL, BY PRESSING ` OR CLICKING HERE. THOUGHTCRIME IS DEATH.
§ 01
National Institute of Technology, Tiruchirappalli
B.Tech, Instrumentation & Control Engineering (Minor: Computer Applications)
Indian Institute of Technology Madras
BS, Data Science & Applications
§ 02
Technical Head at Robotics and Machine Intelligence (RMI), NIT Trichy
Ex-Secretary at Toastmasters NITT Chapter
BioRob, EPFL · JUN 2026 TO AUG 2026
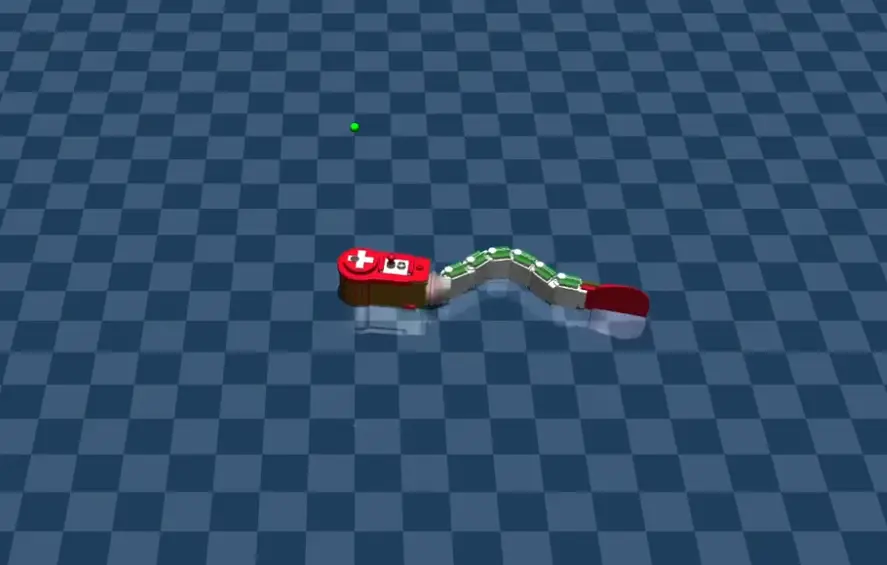
Ported a bio-inspired zebrafish-larva swimming robot from Webots to MuJoCo/FARMS, then fixed two physics defects in the lab's underwater simulation stack: a fixed-point buoyancy model and a hard-coded fluid density.
ON FILE:REPORTPRESENTATION
R2D2 / Thryv Mobility, IIT Madras · MAY 2025 TO JUL 2025
Derived a state-space model of wheelchair push dynamics from strain-gauge data collected across 40 subjects, and implemented a cruise-control proof of concept.
NIT Trichy · DEC 2024 TO PRESENT
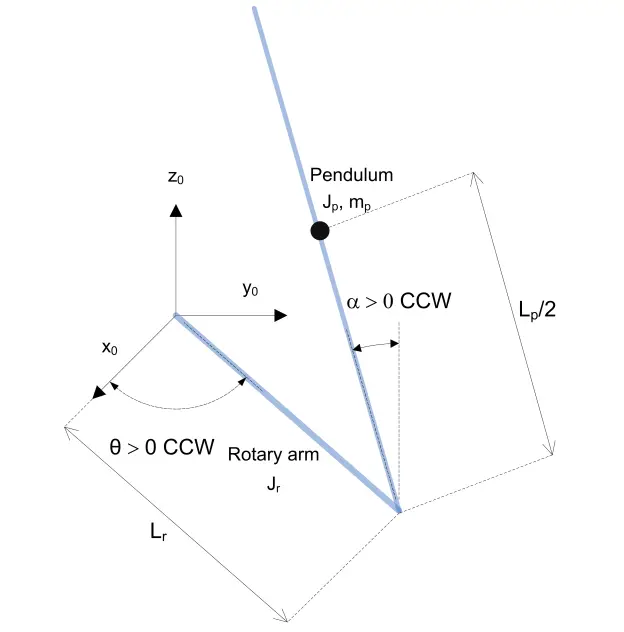
Linearized and stabilized a Quanser rotary inverted pendulum using pole placement, LQR, and gain-scheduled LQR, validated on real hardware.
ON FILE:SHORT REPORT
RMI, NIT Trichy · DEC 2024 TO PRESENT
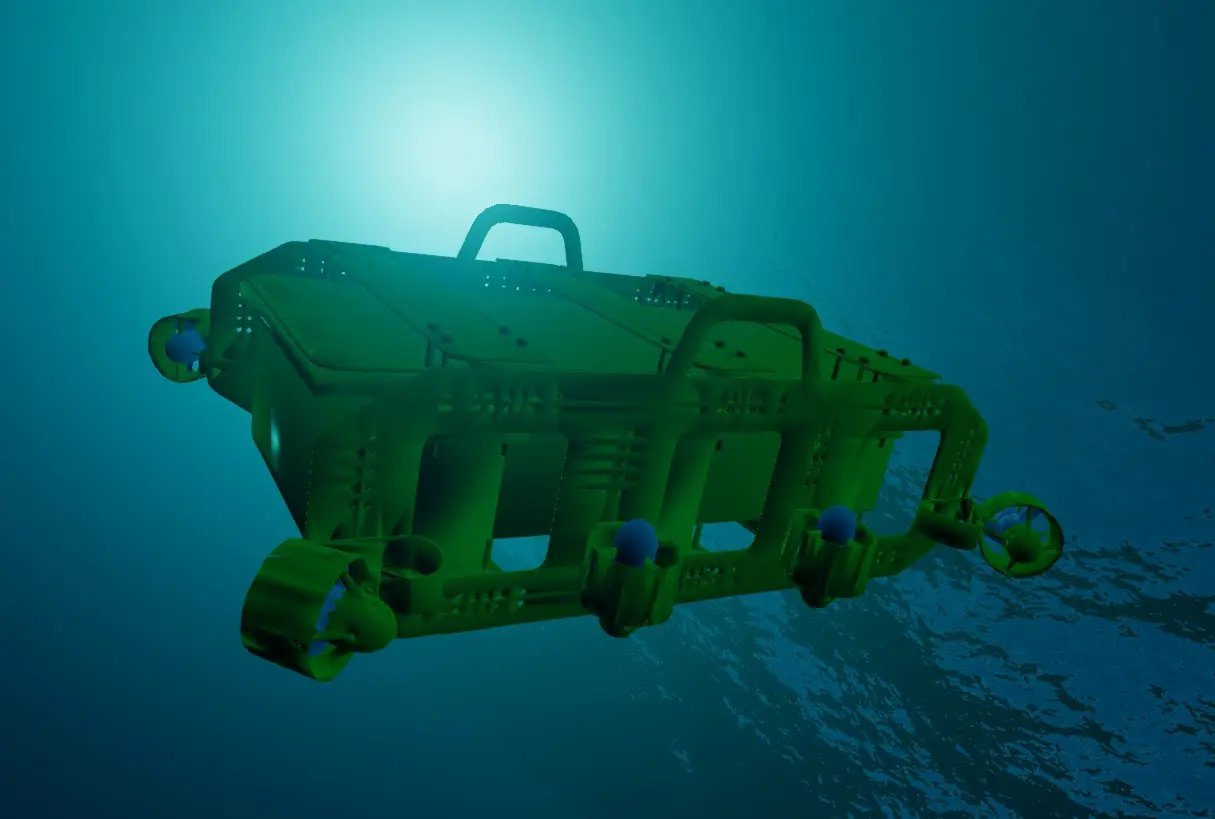
RMI's eight-thruster, 6-DOF underwater vehicle: I sealed its enclosure, then built a simulated autonomy stack in Stonefish: thruster allocation, cascaded control, AprilTag localization and a monocular coral-mapping pipeline trained on auto-labelled images.
ON FILE:SHORT REPORTREPORT
Independent · AUG 2026 TO SEP 2026
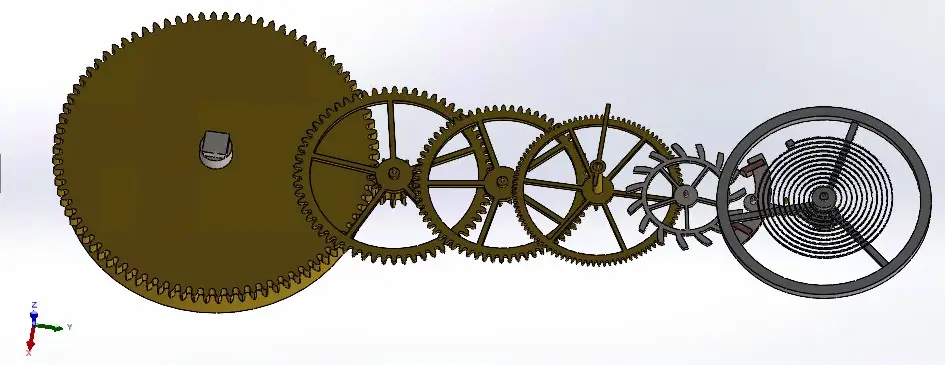
The basic mechanism of a mechanical watch, from mainspring barrel to balance, designed from first principles: thirteen parts driven by 393 linked equations, ogival NIHS 20-30 teeth, a Monte Carlo tolerance study, and a full contact simulation that ticks at 0.2498 s against a design value of 0.2500 s.
ON FILE:SHORT REPORTREPORT
RMI, NIT Trichy · SEP 2025 TO DEC 2025
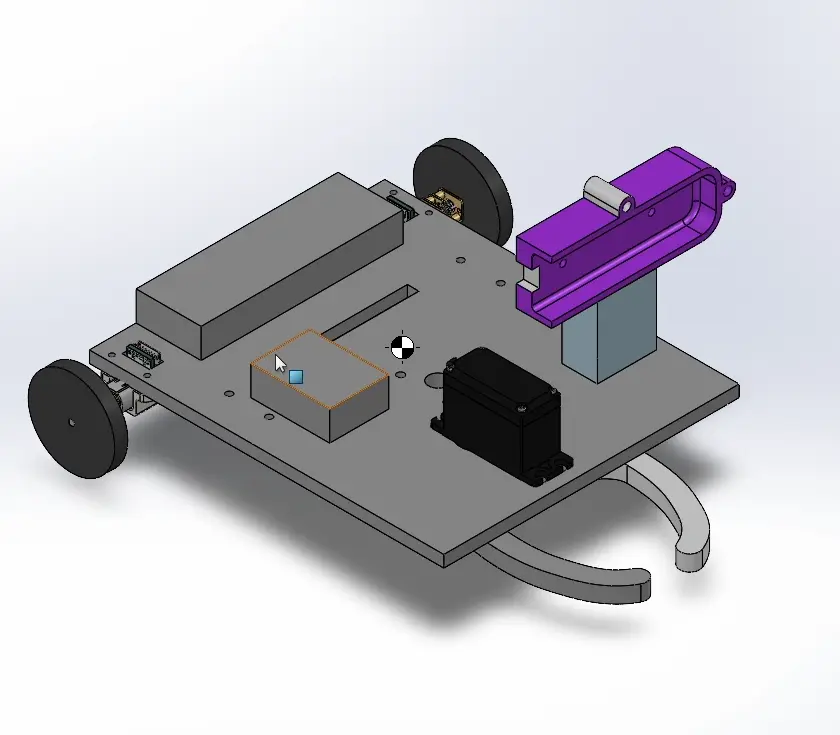
A 3D-printed differential-drive robot designed for a WorldSkills pick-and-place task: a caging gripper slides coins without lifting, RTAB-Map and Nav2 navigate around obstacles, and a line follower guides the final blind docking. 36 of 36 coins delivered across twelve simulated missions.
ON FILE:SHORT REPORTREPORT
§ 05
LQR ControlKinematics & DynamicsObserver DesignSystem ModelingSimulinkOpenCVDockerESP-IDFRaspberry PiArduino
§ 06
District-Level Toastmasters Humorous Speech Contest
District-Level Toastmasters Speech Evaluation Contest